Research

Provably correct, real-time algorithms for autonomous dynamical systems.

Research areas

Trajectory Optimization

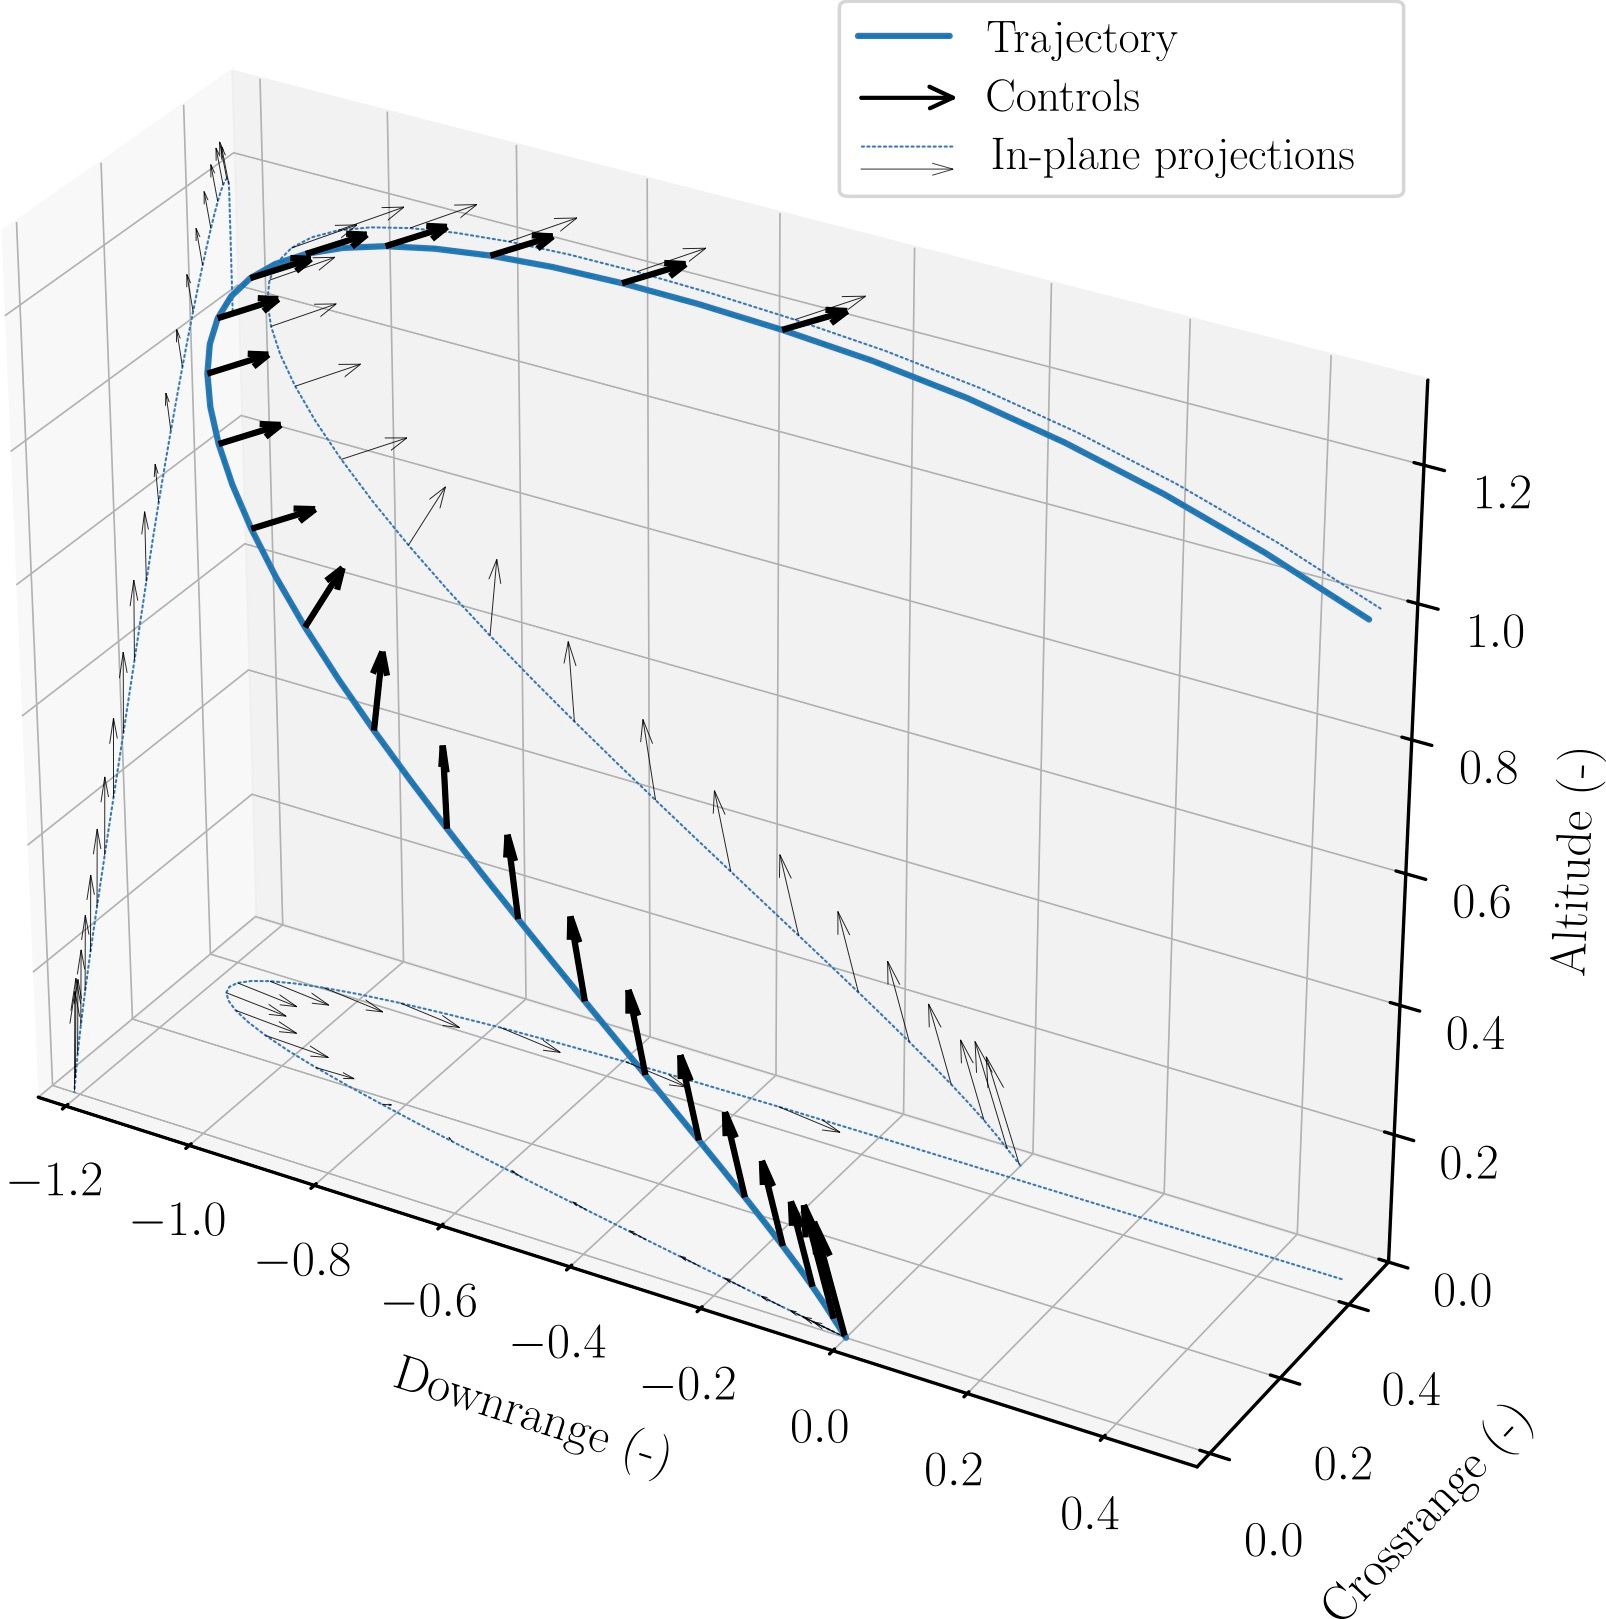
We study onboard computation of optimal trajectories for systems with nonconvex dynamics and constraints. Lossless convexification shows that selected nonconvex optimal control problems can be solved exactly through convex relaxations. Examples include fuel-optimal planetary landing with minimum-thrust and pointing constraints. Successive convexification (SCvx) extends the approach to nonlinear dynamics, including recent guarantees for continuous-time constraint satisfaction.
Convex Optimization Algorithms

Flight-grade autonomy needs solvers with predictable runtime and limited memory use. The lab designs first-order methods and conic solvers for embedded platforms. QOCO, an open-source quadratic-objective conic optimizer, is one example.

Robust Control

Real systems face disturbances, model uncertainty, and actuation limits. The lab develops feedback synthesis methods that preserve constraint satisfaction under uncertainty. One example is robust fuel-optimal trajectory planning with feedback control.

Optimal Recursive Decision-Making

Many autonomy problems are sequential. Current decisions change what will be feasible later. The lab formulates recursive decision-making problems with temporal and logical specifications, then studies convex formulations that make optimal policies computationally tractable.

Markov Decision Processes

For large-scale stochastic systems, the lab studies density control and policy synthesis on Markov decision processes. Spacecraft and vehicle swarms are the motivating cases. The goal is probabilistic guidance with safety and convergence guarantees.

Selected projects

Click any project to see details, results, and media.

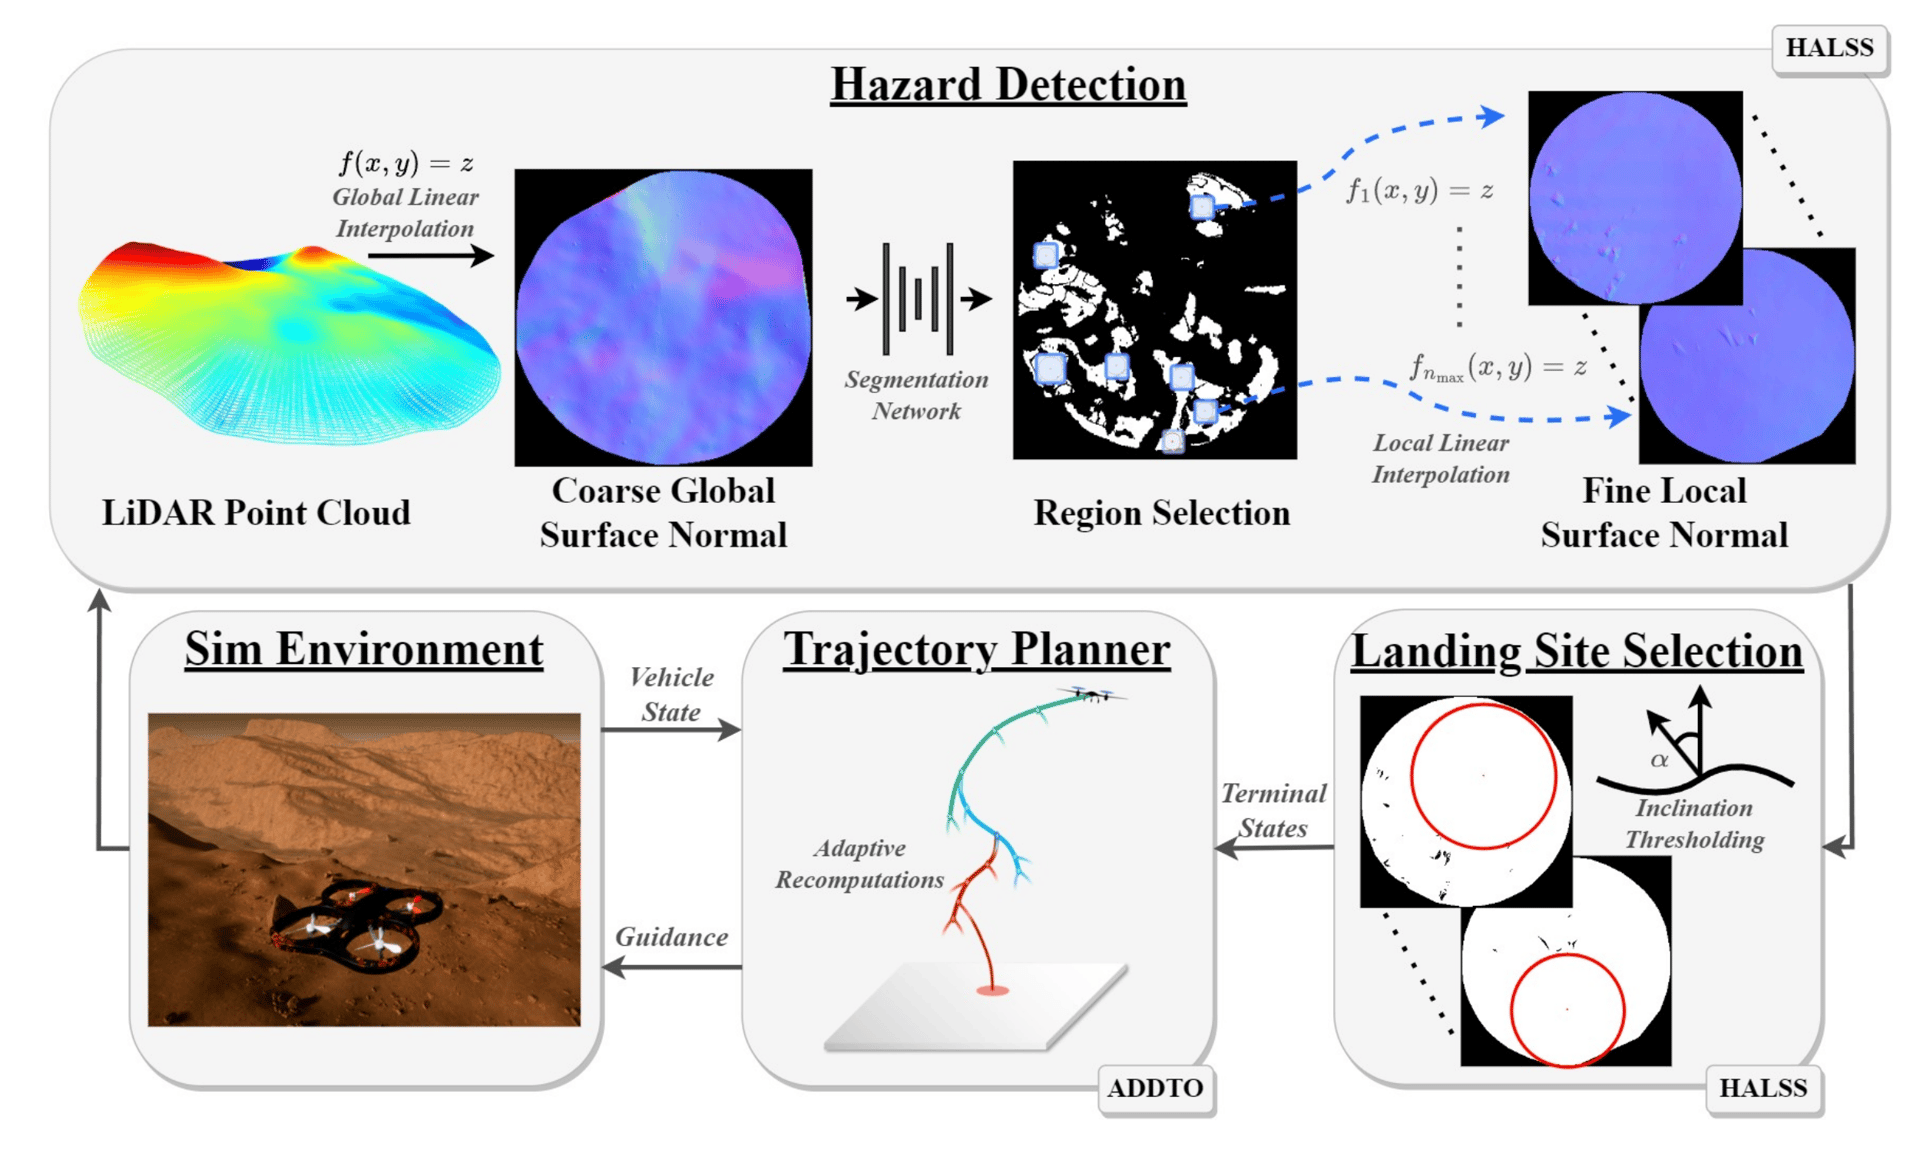
HALO: Hazard-Aware Landing Optimization

Coupled perception and trajectory optimization for safe landing site selection and divert guidance on hazardous terrain.

Perception, contingency planning, AirSim simulation

QOCO Solver

An open-source quadratic-objective conic optimizer designed for real-time, embedded trajectory optimization workloads.

C solver, custom generation, conic programs

Continuous-Time SCvx

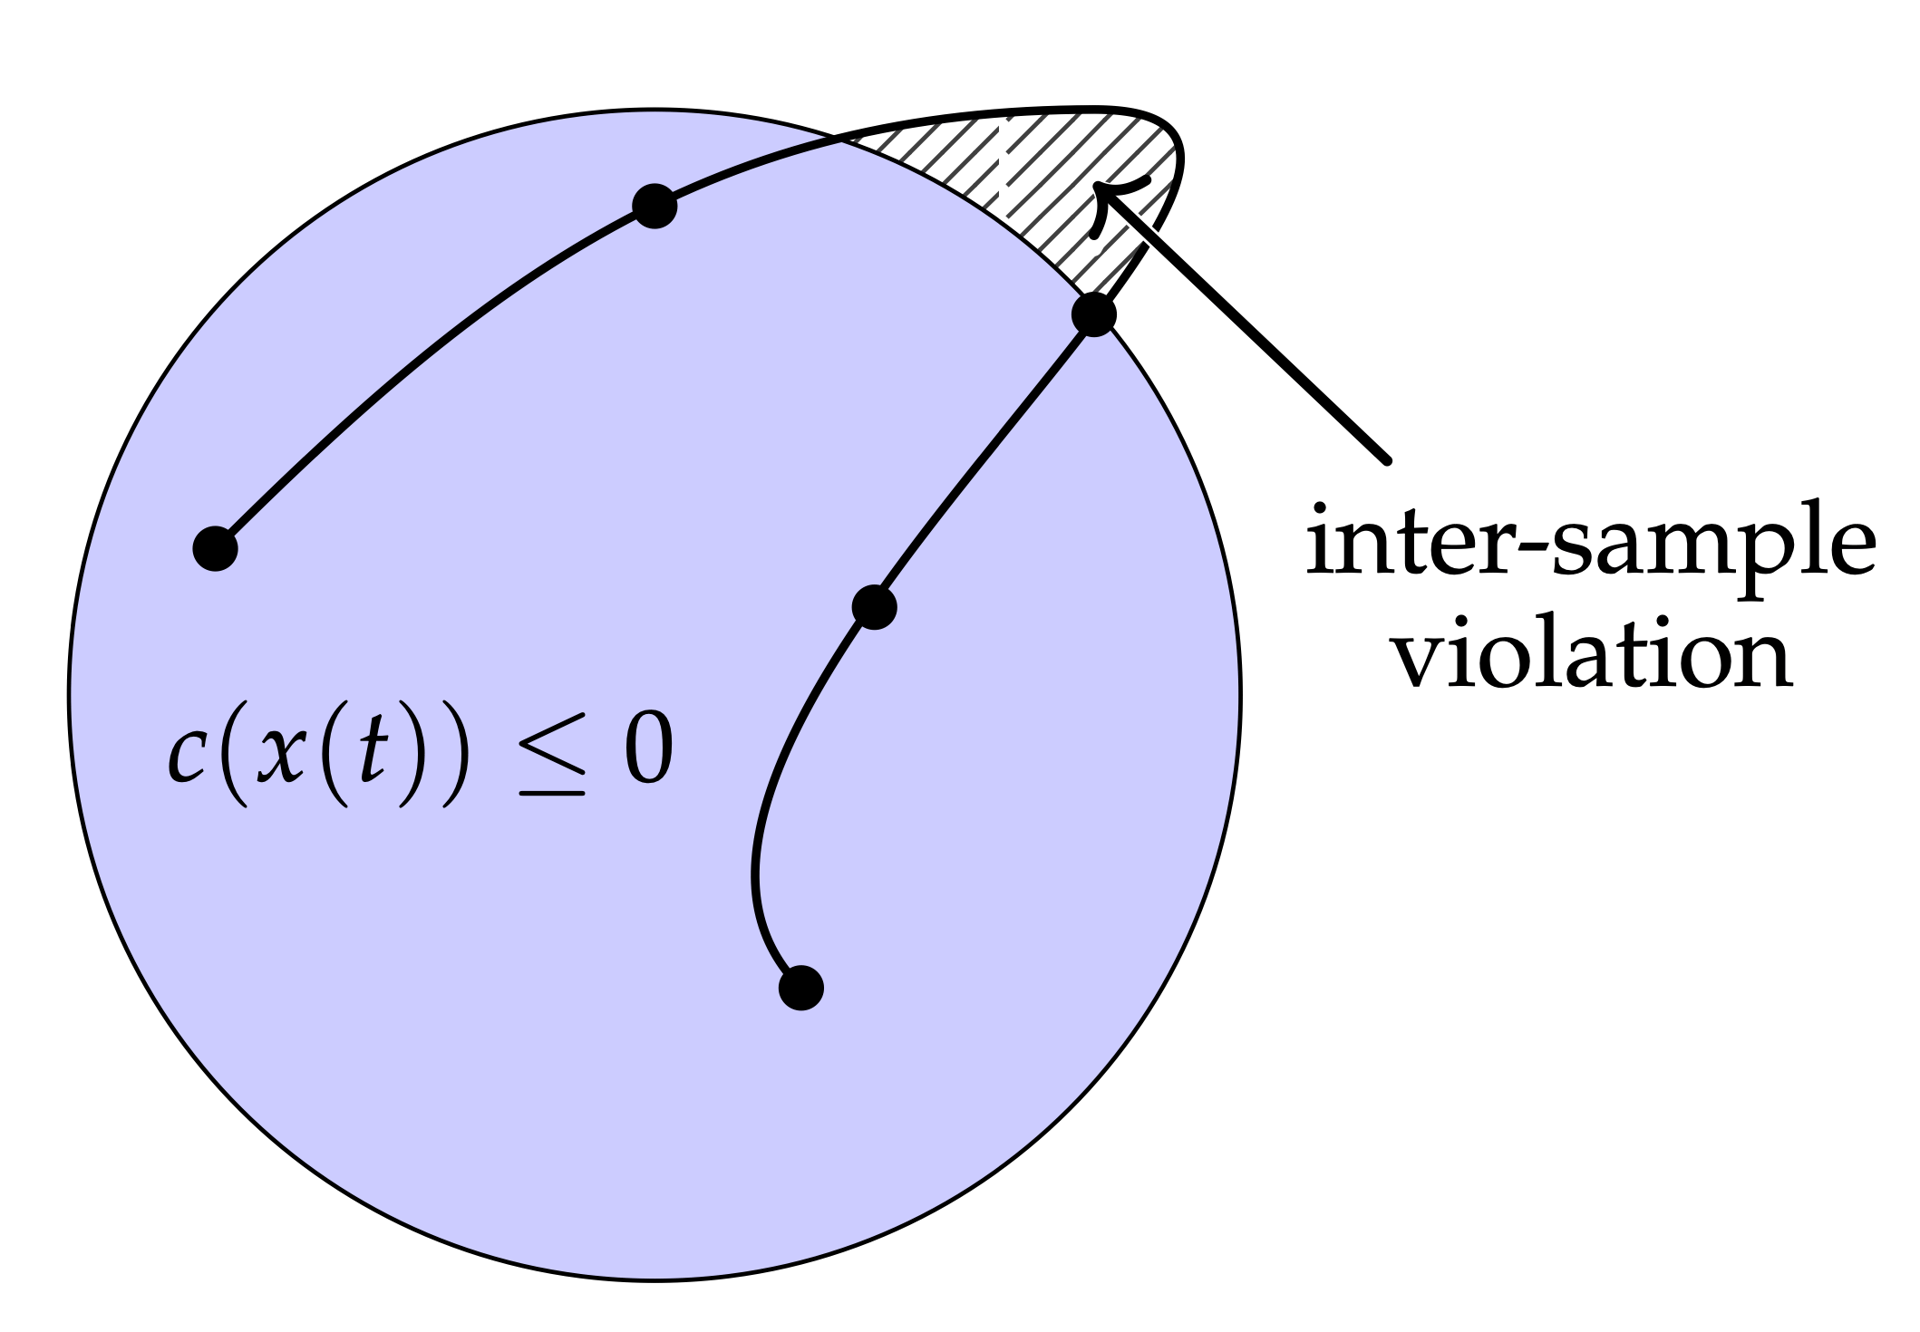
Successive convexification with continuous-time constraint satisfaction and elimination of inter-sample constraint violations.

Rocket landing, obstacle avoidance, sparse grids

Cislunar Relative Motion

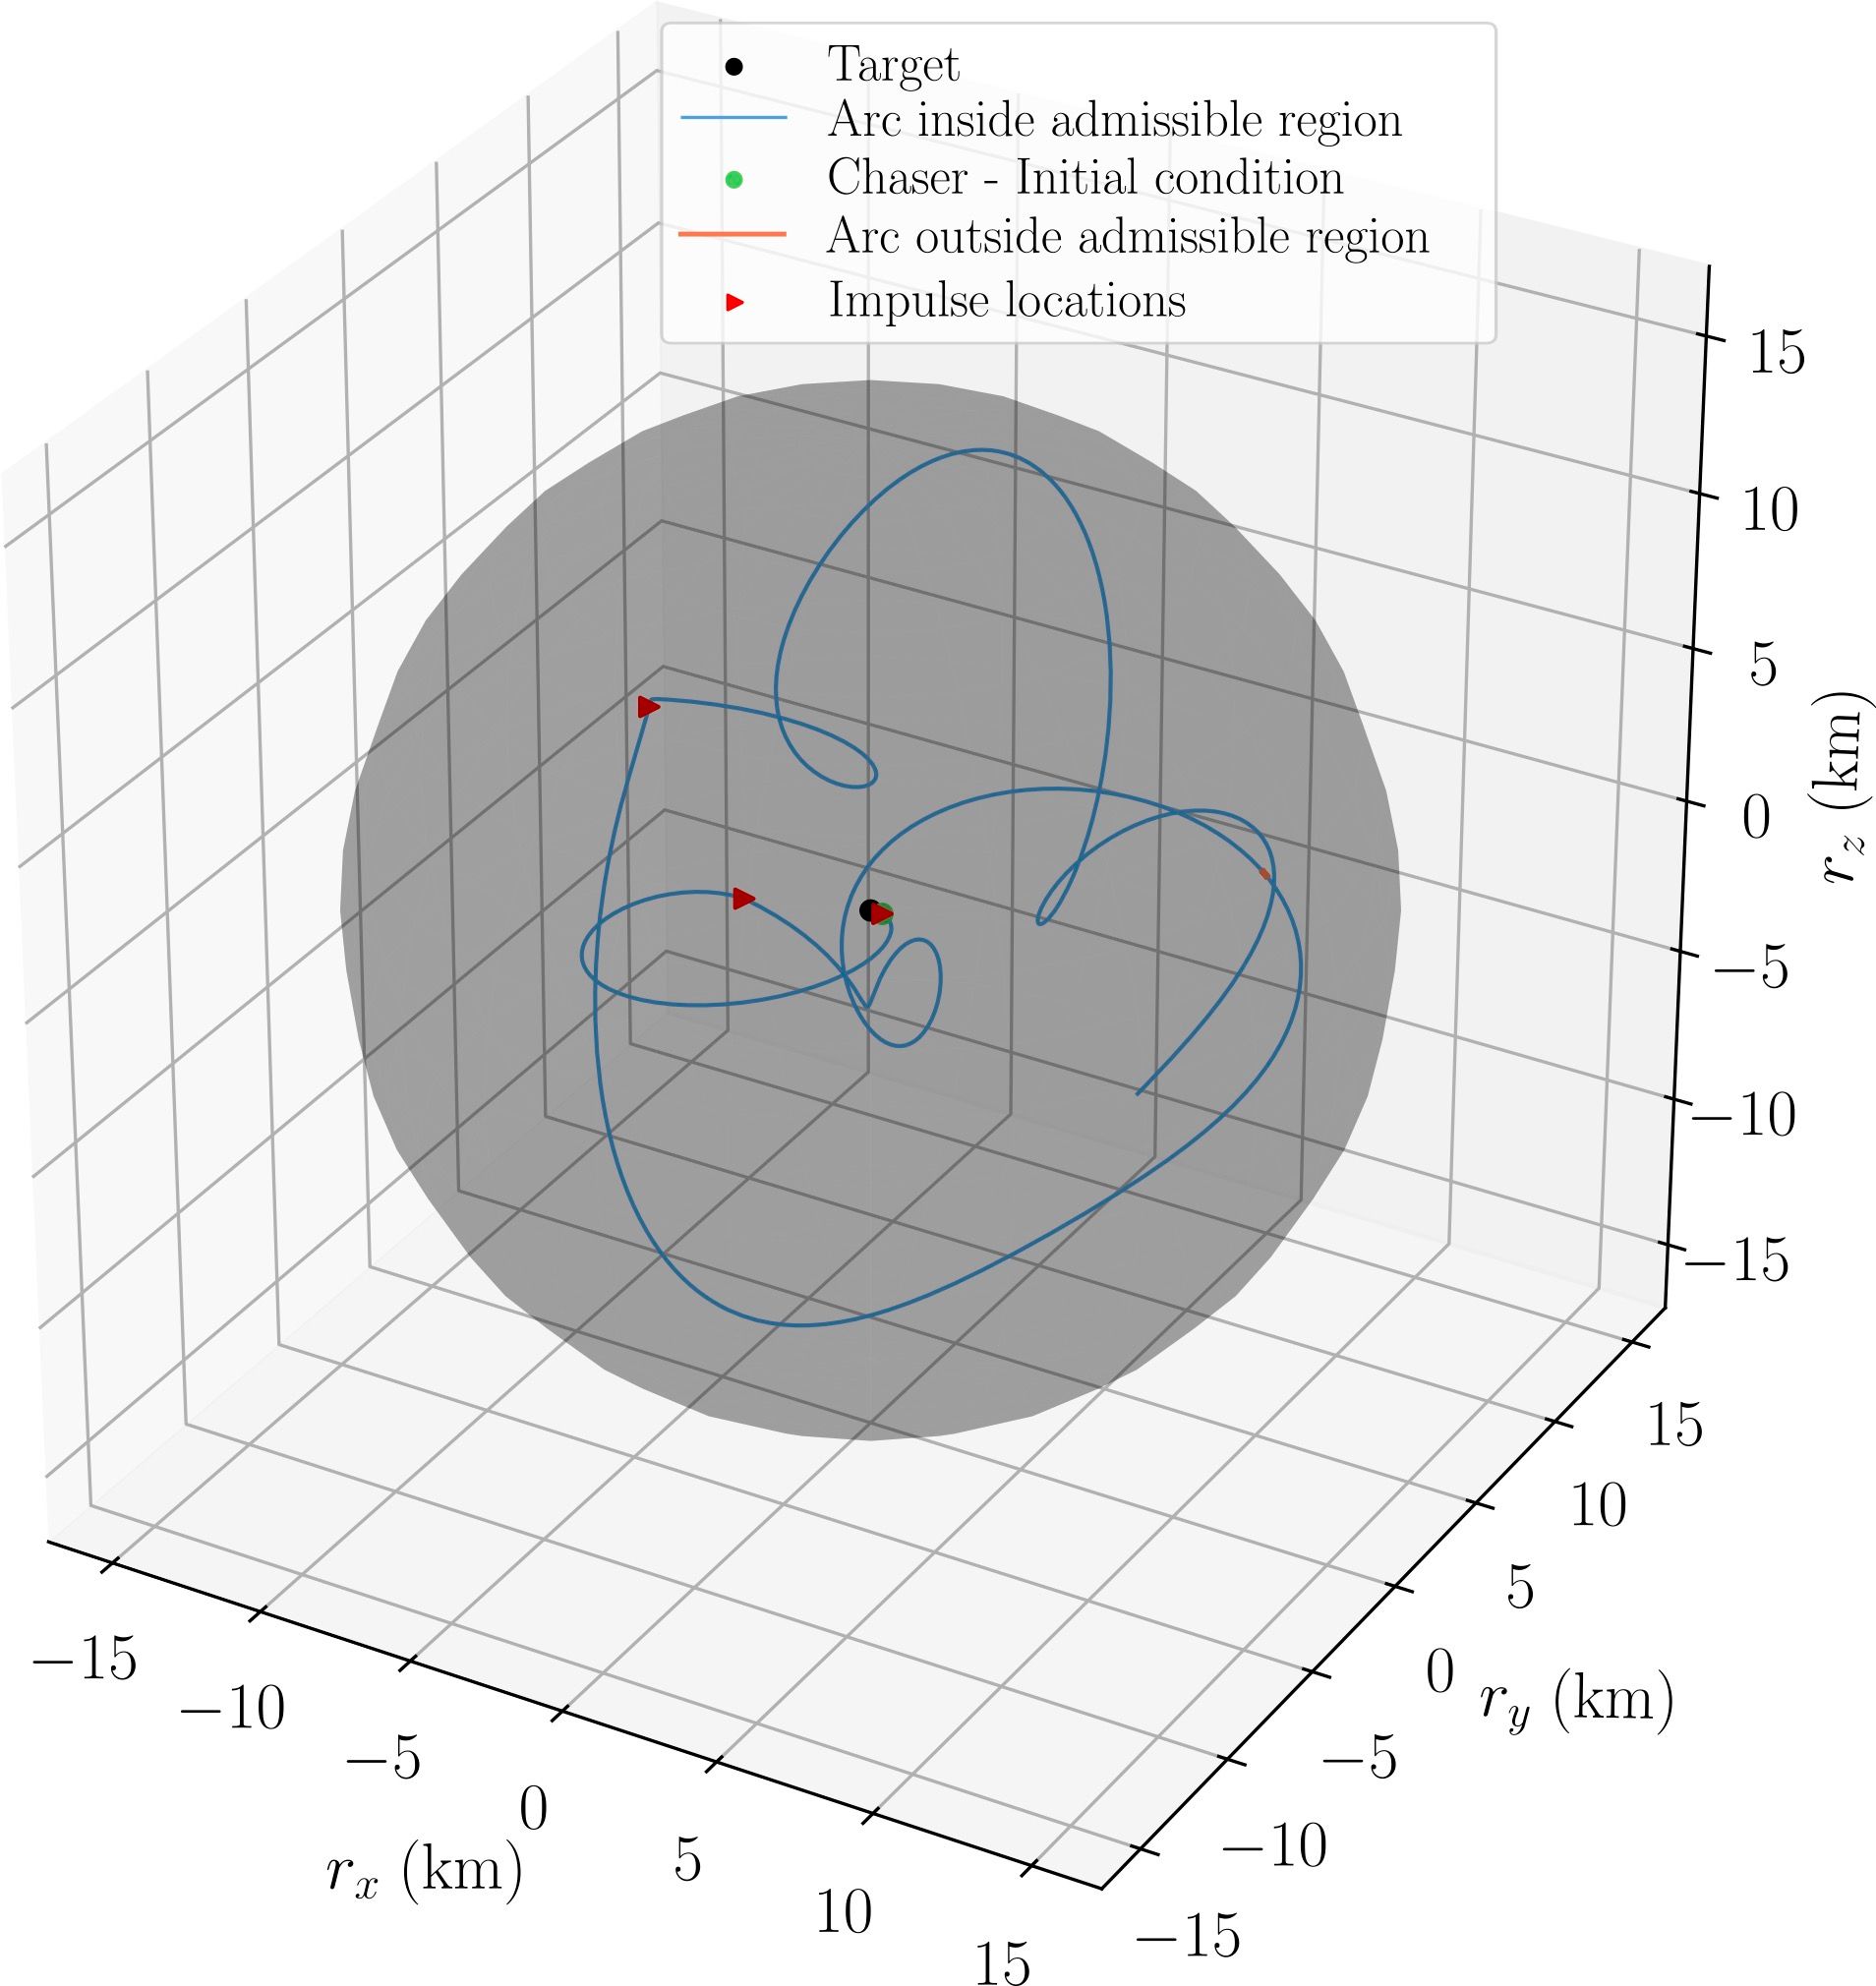
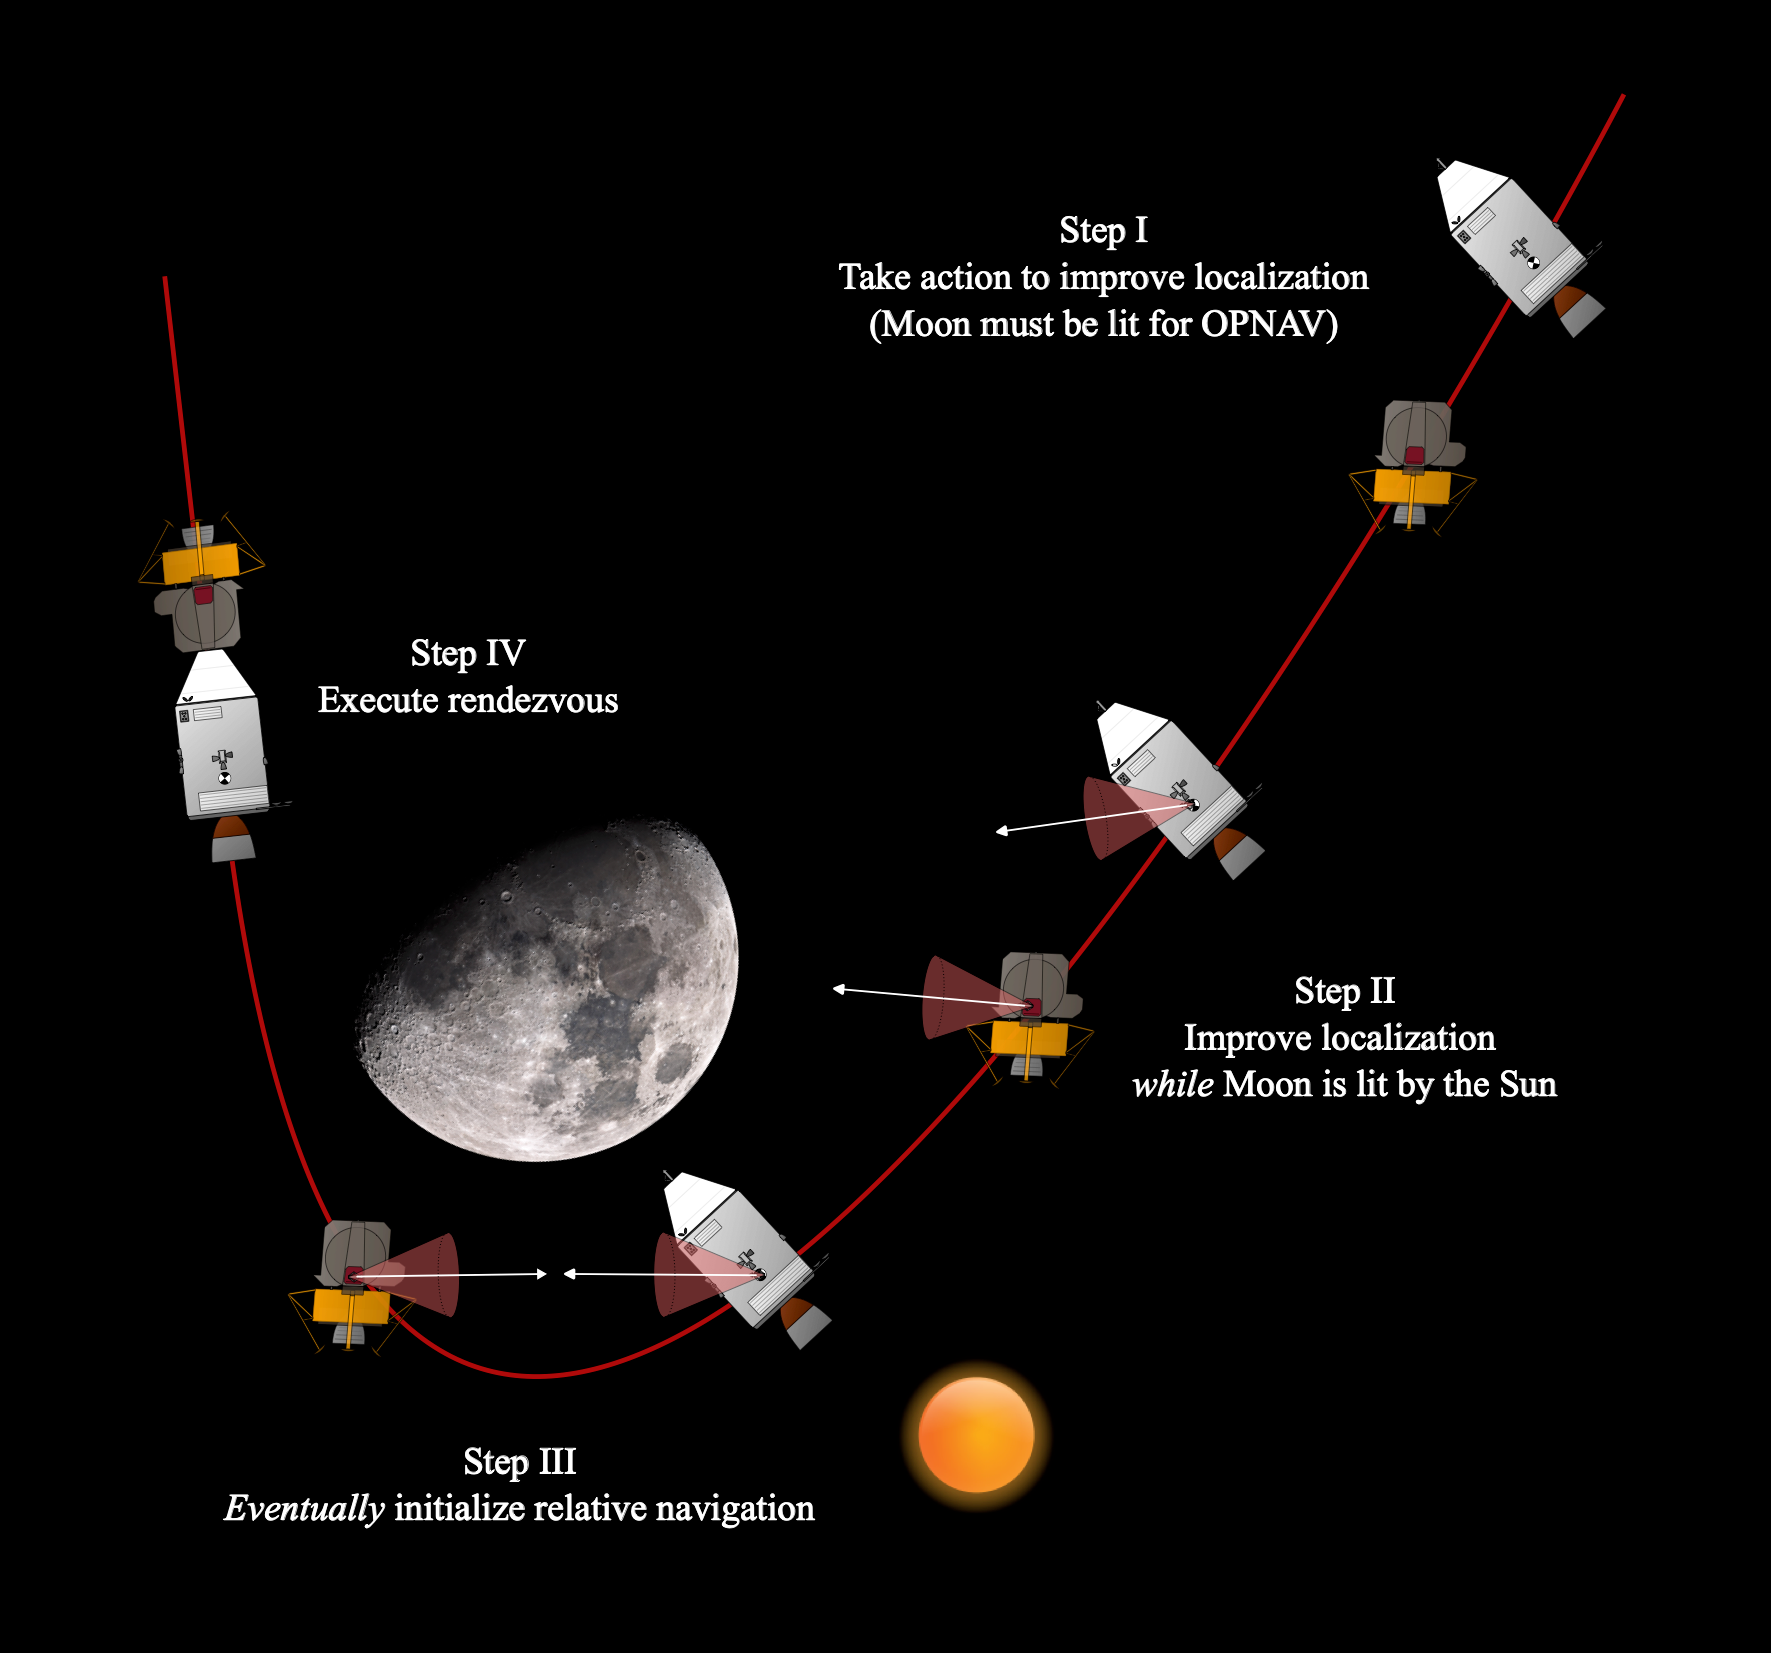
Impulsive relative motion control for rendezvous and proximity operations in cislunar space missions.

NRHO dynamics, finite impulses, path constraints

Discrete Lossless Convexification

Extending lossless convexification to discrete-time problems with pointing constraints.

Discrete-time guidance, pointing cones, relaxations

Temporal & Logical Specifications

Optimization-based planning under rich mission specifications expressed in temporal and propositional logic.

STL, D-GMSR, mission-rule satisfaction

See Publications for papers associated with each project, and Software for open-source code.